Automatique & Robotique

The Robot Revolution: How Robots Will Change the Way We Live and Work | Shapers of Tomorrow (6/8)
La Révolution des robots : Comment les robots changeront notre façon de vivre et de travailler | Shapers of Tomorrow (6/8)
★
★
★
★
☆
4/5

Pasado, presente y futuro de la robótica en relación a la IA
Passé, présent et futur de la robotique en relation avec l'IA
★
★
★
☆
☆
3/5

Every Confusing Thing About Robotics Explained Slowly (For Sleep)
Chaque chose confuse à propos de la robotique expliquée lentement (pour dormir)
★
★
★
★
☆
4/5



EMBEDDED PLATEFORMS | INTERNET OF THINGS | LECTURE 02 BY MS. BABITA RAJPUT | AKGEC
PLATEFORMES EMBARQUÉES | INTERNET DES OBJETS | COURS 02 PAR MS. BABITA RAJPUT | AKGEC
★
★
★
☆
☆
3/5
GPIO OUTPUT WITH ESP 32 & MICROPYTHON | IOT | LECTURE 01 BY MR. HIMANSHU TRIPATHI | AKGEC
SORTIE GPIO AVEC ESP 32 ET MICROPYTHON | IOT | LECTURE 01 PAR MR. HIMANSHU TRIPATHI | AKGEC
★
★
★
★
☆
4/5

BLOCK DIAGRAM REDUCTION | CONTROL SYSTEM | LECTURE 05 BY DR. AMIT GARG | AKGEC
RÉDUCTION DE DIAGRAMME DE BLOCS | SYSTÈME DE CONTRÔLE | CONFÉRENCE 05 PAR DR. AMIT GARG | AKGEC
★
★
★
★
☆
4/5
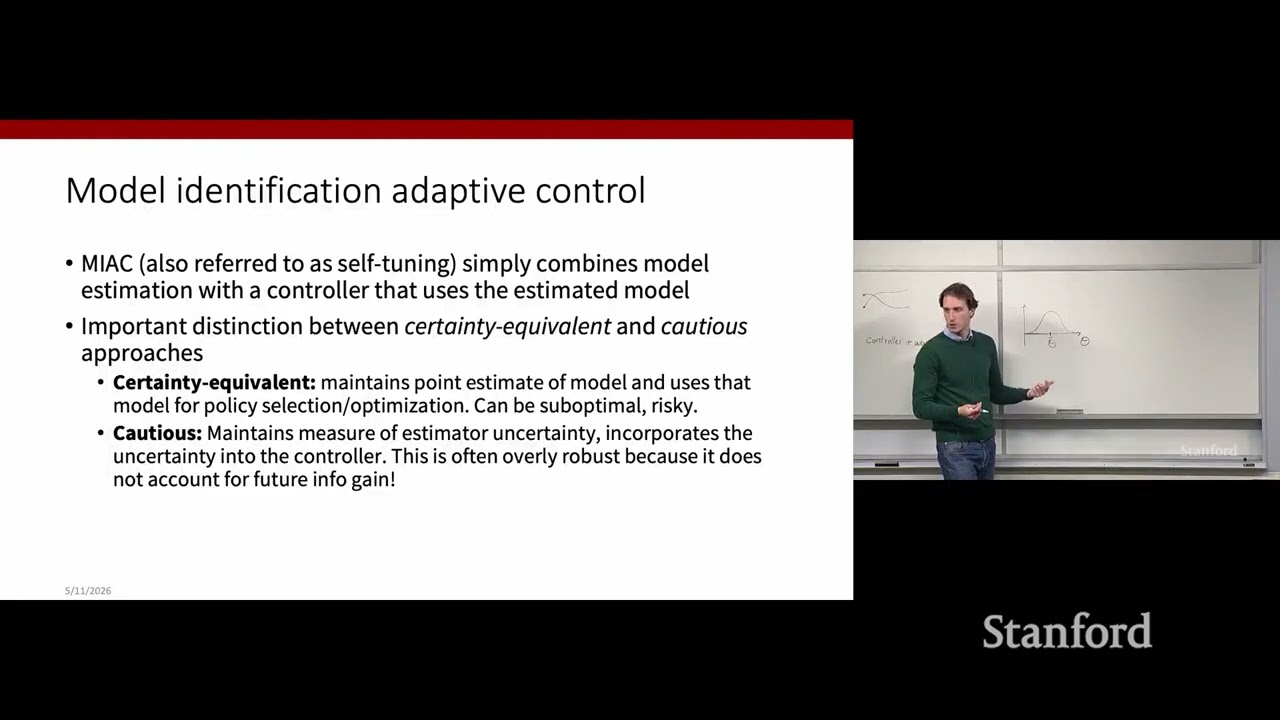
Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 14: Intro to IL and RL
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 14 : Introduction à IL et RL
★
★
★
★
☆
4/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 13: Intro to Learning
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 13 : Introduction à l'apprentissage
★
★
★
★
☆
4/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 12: Feasibility of MPC
Stanford AA203 Contrôle Optimal et Basé sur l'Apprentissage | Printemps 2026 | Leçon 12 : Faisabilité du MPC
★
★
★
★
★
5/5
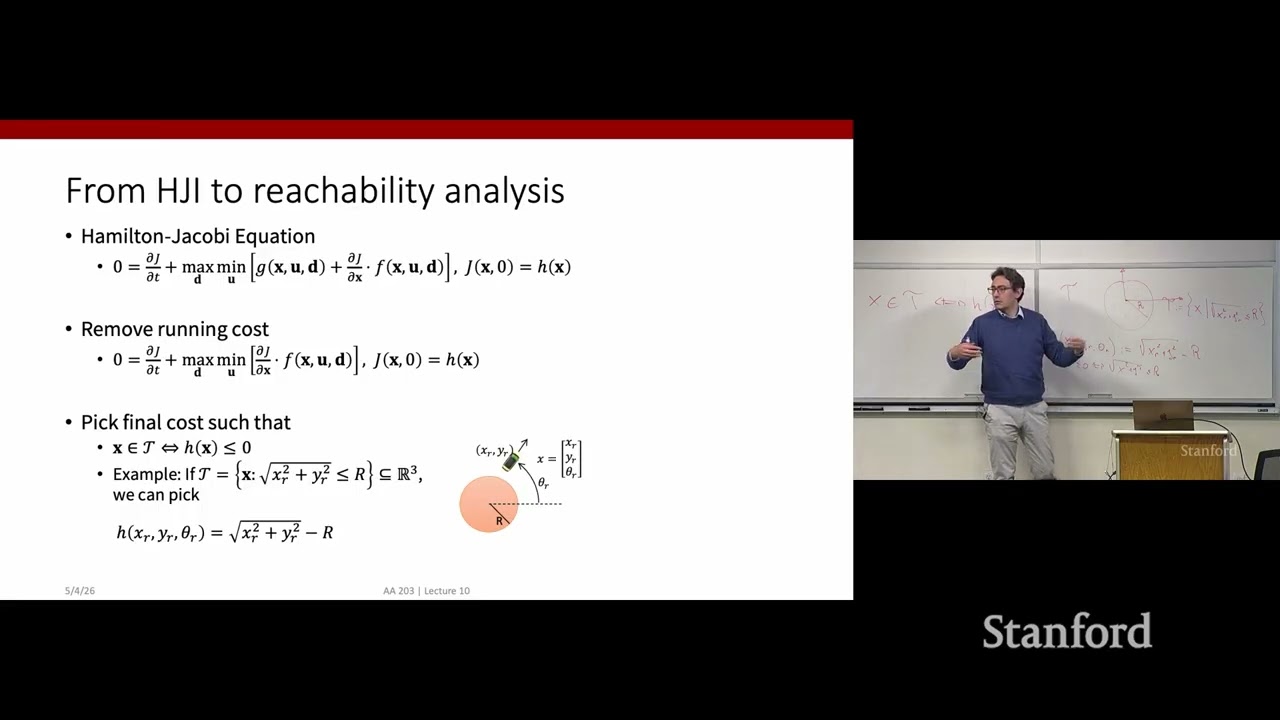
Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 11: Introduction to MPC
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 11 : Introduction à la MPC
★
★
★
★
☆
4/5
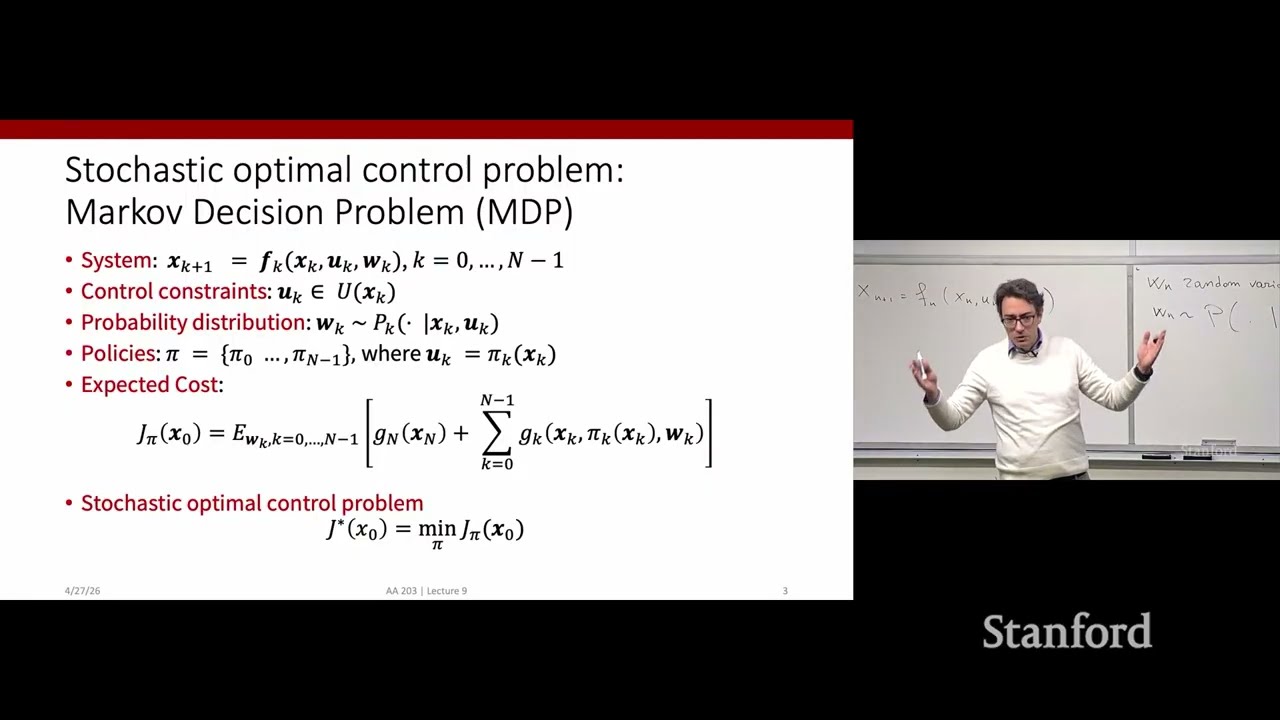
Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 9: Stochastic Dyn. Program
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 9 : Prog. dynamique stochastique
★
★
★
★
★
5/5
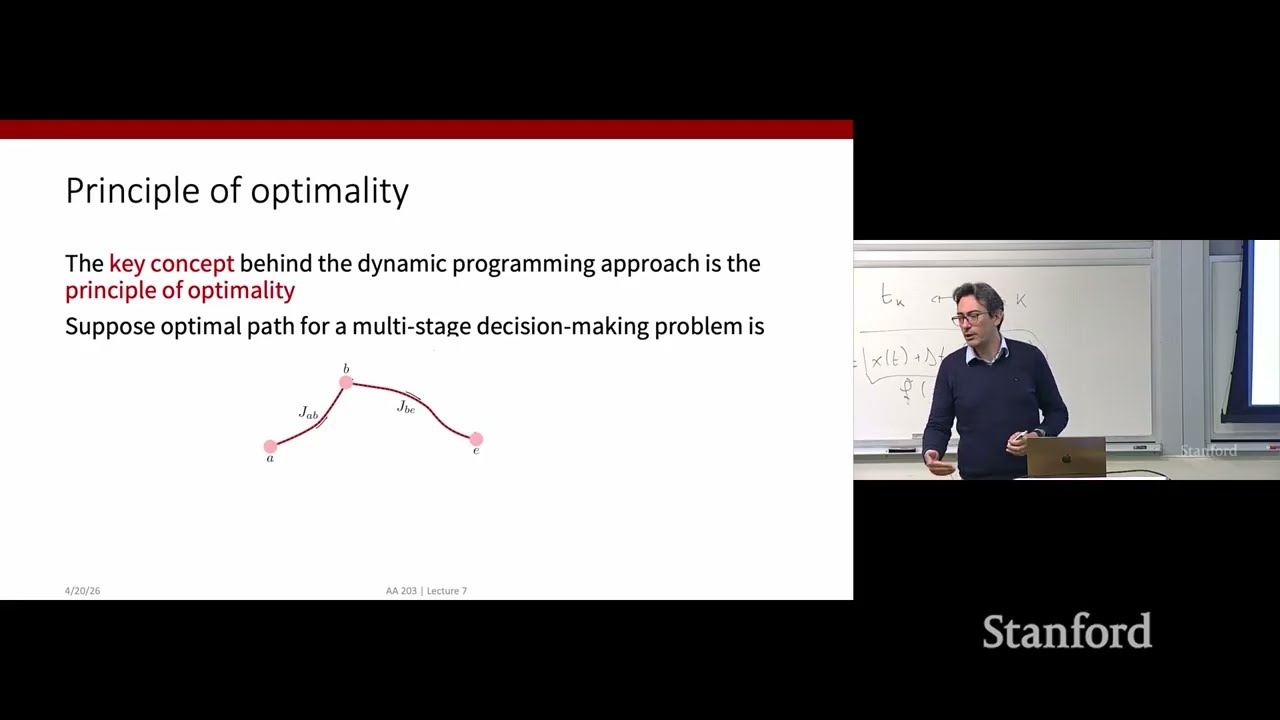
Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 7: Dynamic Programming
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 7 : Programmation dynamique
★
★
★
★
★
5/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 6: Direct Methods
Stanford AA203 Contrôle optimal et par apprentissage | Printemps 2026 | Cours 6 : Méthodes directes
★
★
★
★
☆
4/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 10: Reachibility Analysis
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Conférence 10 : Analyse d'accessibilité
★
★
★
★
★
5/5
Mai mult decât roboți | Sebastian Tănase | TEDxCopou Youth
Plus que des robots | Sebastian Tănase | TEDxCopou Youth
★
★
★
☆
☆
3/5

AStanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 8: LQR-Style Algorithms
AStanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 8 : Algorithmes de type LQR
★
★
★
★
★
5/5
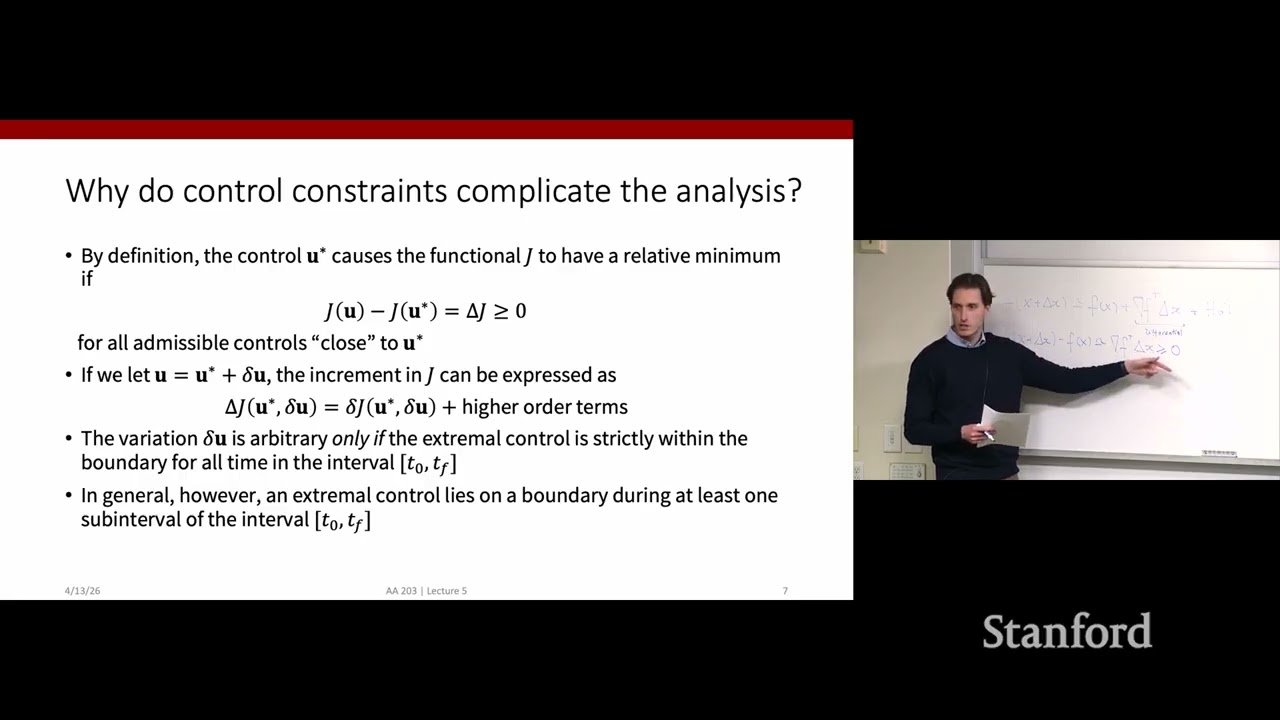
Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 5: Computational Methods
Stanford AA203 Contrôle optimal et par apprentissage | Printemps 2026 | Cours 5 : Méthodes de calcul
★
★
★
★
★
5/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 4: Indirect Methods
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 4 : Méthodes indirectes
★
★
★
★
☆
4/5

Stanford AA203 Optimal and Learning-Based Control | Spring 2026 | Lecture 1: Course Overview
Stanford AA203 Contrôle optimal et basé sur l'apprentissage | Printemps 2026 | Cours 1 : Aperçu du cours
★
★
★
★
★
5/5

Learn Robot Manipulation with LeRobot and ROS 2 | NVIDIA Jetson AI Lab
Apprendre la manipulation robotique avec LeRobot et ROS 2 | NVIDIA Jetson AI Lab
★
★
★
★
☆
4/5


ROOT LOCUS | CONTROL SYSTEM | LECTURE 02 BY DR. AMIT GARG | AKGEC
ROOT LOCUS | SYSTÈME DE CONTRÔLE | CONFÉRENCE 02 PAR DR. AMIT GARG | AKGEC
★
★
★
★
☆
4/5
POLAR PLOT & NYQUIST PLOT | CONTROL SYSTEM | LECTURE 01 BY DR. AMIT GARG | AKGEC
POLAR PLOT & NYQUIST PLOT | SYSTÈME DE CONTRÔLE | CONFÉRENCE 01 PAR DR. AMIT GARG | AKGEC
★
★
★
★
☆
4/5

Stanford Robotics Seminar ENGR319 | Winter 2025 | Embodied Intelligence
Séminaire de robotique de Stanford ENGR319 | Hiver 2025 | Intelligence incarnée
★
★
★
★
☆
4/5
Build and Optimize Robotics and Edge AI with the New Jetson Thor T2000 and T3000
Construisez et optimisez la robotique et l'IA de périphérie avec les nouveaux Jetson Thor T2000 et T3000
★
★
★
★
☆
4/5

America Is Now Building Humanoid AI Robot Soldiers for War
L'Amérique fabrique désormais des robots humanoïdes militaires dotés d'IA pour la guerre
★
★
★
★
☆
4/5

Day 4 - Autonomous Operation (guest lecture) - Longo
Day 4 - Opération autonome (conférence invitée) - Longo
★
★
★
★
☆
4/5


Every Confusing Thing About Control Systems Explained Slowly (For Sleep)
Chaque chose confuse à propos des systèmes de contrôle expliquée lentement (pour dormir)
★
★
★
★
☆
4/5

It's Control System Integrity not just OT Cybersecurity
C'est l'intégrité des systèmes de contrôle, pas seulement la cybersécurité OT
★
★
★
☆
☆
3/5
